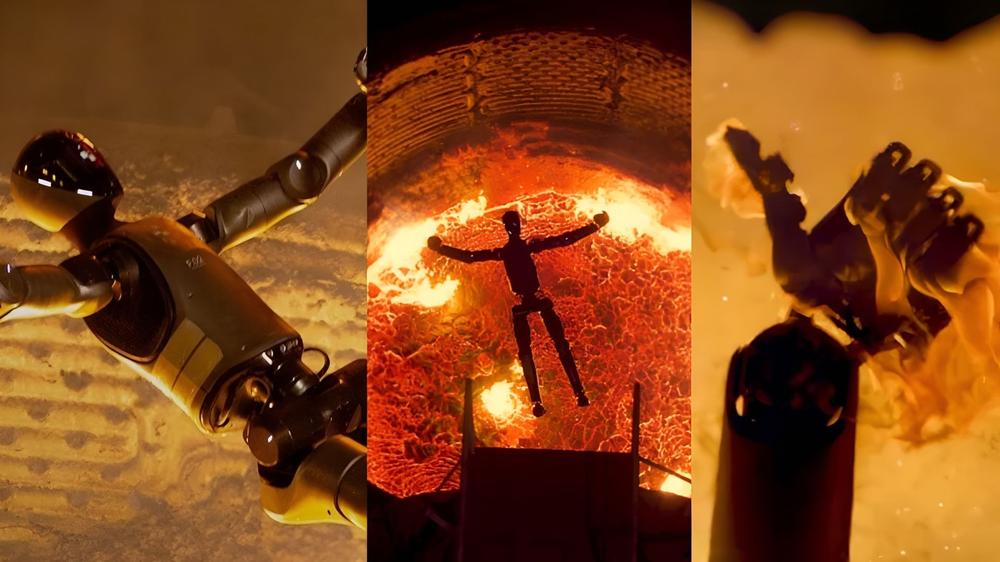
Interesting Engineering · 原标题:Humanoid robot fleet decommissioned in wild Terminator-style leap into molten steel
Figure 为其退役的人形机器人安排了一场戏剧化的告别:数台机器人纵身跃入熔融钢水中。公司称这一“终结者式”的退役方式既是对旧机型的物理销毁,也意在展示人形机器人在极端工业环境下的耐用性与最终处置方案。
Figure 为其退役的人形机器人安排了一场戏剧化的告别:数台机器人纵身跃入熔融钢水中。公司称这一“终结者式”的退役方式既是对旧机型的物理销毁,也意在展示人形机器人在极端工业环境下的耐用性与最终处置方案。
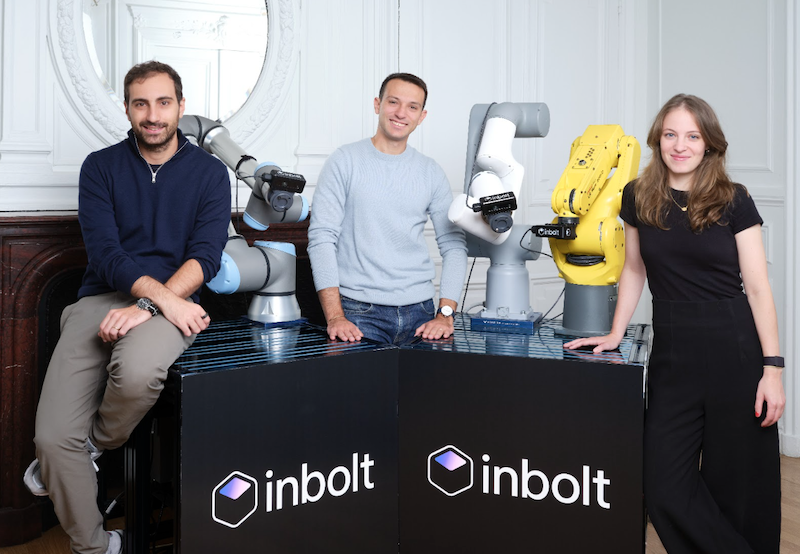
工业机器人视觉与智能方案商 Inbolt 宣布完成 1250 万美元融资,由 Shift4Good 领投,Bridges Climate Transition Partners 参投。其技术让工业机器人在产线中实时“看见”、思考并自适应调整,用于装配、焊接等场景。
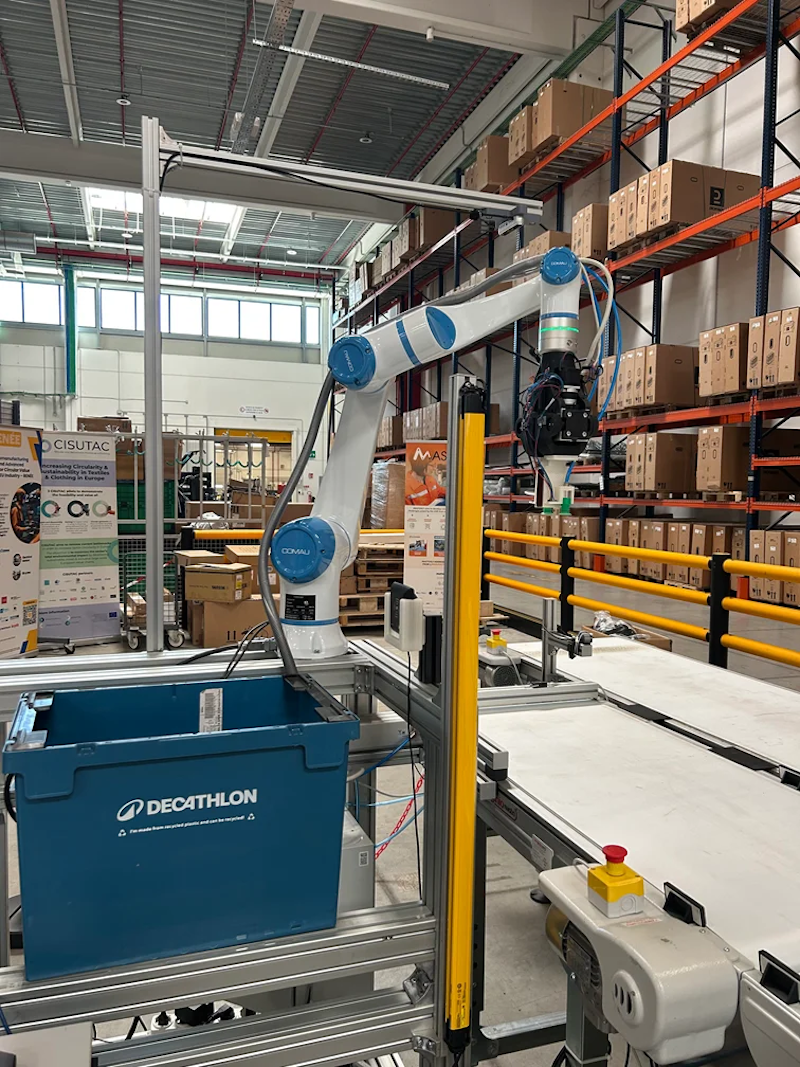
Comau 在欧盟“MASTERLY”项目下,为 Decathlon 电商履约环节设计并验证了一套订单预处理方案。系统基于 Comau MyCo 协作机器人,采用 ROS2 架构并集成智能传感器,旨在推动从大规模生产向高度柔性、定制化制造的转型。
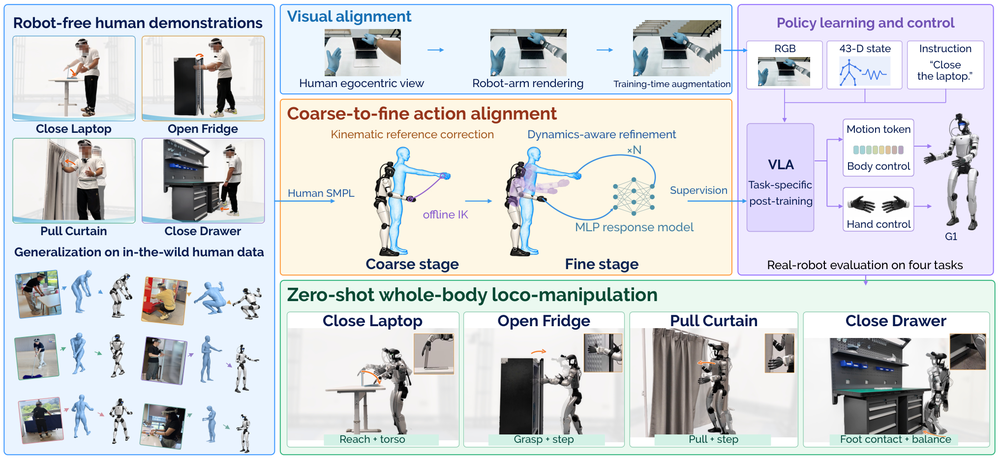
研究人员提出首个以第一人称视角实现人体到人形机器人协调全身 loco-manipulation 技能迁移的框架 EgoHumanoid-V2。该方法无需机器人遥操作,仅通过人类演示即可捕捉多样化场景与全身技能,并直接迁移到人形机器人。